
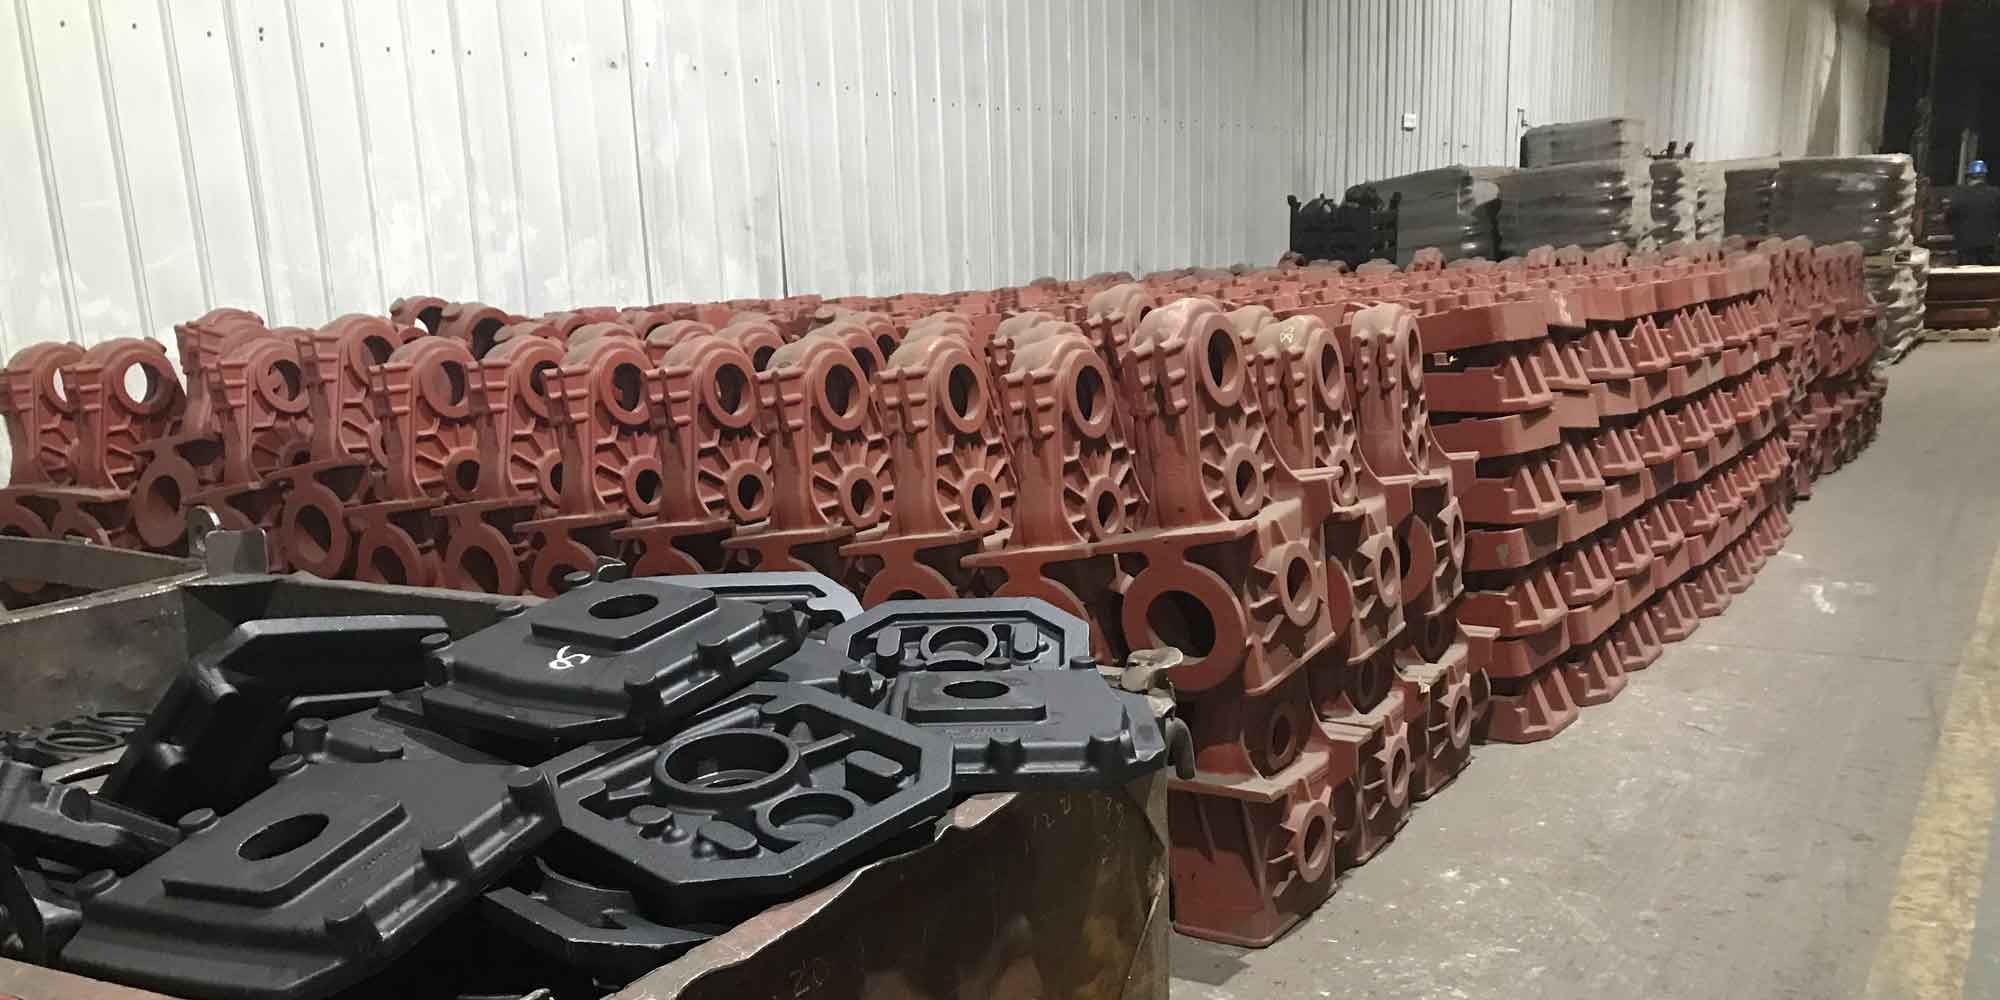
In the manufacturing industry, large and medium-sized steel castings often require subsequent machining operations to achieve the required dimensional accuracy and surface quality. Before machining, however, the cast surfaces frequently contain residual risers, hard sand inclusions, and other imperfections. If these castings are fed directly into CNC machine tools, the hard particles and rough surface layers can severely damage cutting tools and reduce processing efficiency. Therefore, it is necessary to perform a coarse grinding operation prior to precision machining. Traditional manual grinding for steel castings is labor-intensive, dangerous, and exposes workers to dust and noise. In response to these challenges, I have developed an industrial robot-based coarse grinding system for steel castings in collaboration with a foundry enterprise in Qingdao. This paper summarizes my research on tool design, selection, grinding efficiency, grinding force modeling, and structural dynamic analysis.
1. Characteristics and Difficulties of Coarse Grinding for Steel Castings
Coarse grinding is an essential pre-processing step for steel castings. The main goal is to remove large volumes of material efficiently, including risers, parting line flash, surface defects, and embedded sand inclusions. For the steel casting material ZG15Cr2Mo1, the mechanical properties are presented in Table 1.
| Property | Value |
|---|---|
| Tensile strength | 600–724 MPa |
| Yield strength | ≥400 MPa |
| Elongation | ≥21% |
| Reduction of area | ≥40% |
| Hardness | ≤241 HB |
| Impact energy | 115 J |
The typical working conditions for coarse grinding of steel castings include a harsh environment with dust, sparks, and metallic chips. The surface of a steel casting riser is rough, with random peaks and valleys, and the hard sand particles embedded in the material create high-frequency impact forces on the grinding wheel. For this reason, the grinding tool must have both high rigidity to maintain stable material removal and sufficient damping to absorb shocks. The precision requirement is relatively low: a tolerance of 1 mm is acceptable, but the total material removal thickness can exceed 20 mm.
In my design, I identified several key technical difficulties. First, the irregular and hard surface of steel castings causes uneven grinding forces, leading to vibration and potential damage to the robot. Second, conventional six-axis force sensors are expensive and require frequent maintenance in dusty environments. Third, commercial angle grinders with thin disc wheels are inefficient and cannot remove hard sand inclusions. Therefore, I decided to design a new grinding tool from the ground up, using a cylindrical grinding wheel for higher material removal rate and better robustness.
2. Overall System Solution
The robotic grinding system consists of an ABB IRB6700-150 industrial robot and a specially designed end-effector grinding tool. The robot carries the tool and moves it along the steel casting surface. The grinding tool is driven by a servo motor, which provides high torque and allows real-time monitoring of the grinding force through the motor current. This approach eliminates the need for a separate six-axis force sensor, significantly reducing cost and maintenance complexity.
The grinding wheel selected is a resin-bonded brown corundum parallel wheel with an initial diameter of 300 mm and a width of 25 mm. The wheel operates at a peripheral speed between 35 m/s and 45 m/s. The required speed range is achieved by a synchronous belt drive with a speed-increasing ratio of 1:1.5. A buffer structure made of four cylindrical rubber springs is installed between the robot flange and the tool body to absorb shock and vibration during grinding.
3. Design and Selection of Key Components
3.1 Servo Motor Selection
The grinding force was estimated to be less than 150 N in the tangential direction. Considering the wheel diameter and transmission efficiency, the required motor torque and speed were calculated as follows:
$$T_r \geq \frac{F_{t,max} \cdot D_{s,max}}{2 \mu i}$$
$$n_r \geq \frac{60 V_{s,min}}{\pi i D_{s,min}}$$
Substituting the values \(F_{t,max}=150\,\text{N}\), \(D_{s,max}=0.3\,\text{m}\), \(D_{s,min}=0.223\,\text{m}\), \(i=1.5\), \(\mu=0.9\), and \(V_{s,min}=35\,\text{m/s}\), the motor must provide a rated torque of at least 16.67 N·m and a rated speed of at least 1999 r/min. I selected the Delta ECMA-F11830 AC servo motor, whose parameters are listed in Table 2.
| Parameter | Value |
|---|---|
| Rated power | 3.0 kW |
| Rated torque | 19.10 N·m |
| Maximum torque | 57.29 N·m |
| Rated speed | 2000 r/min |
| Maximum speed | 3000 r/min |
| Rotor inertia | 54.95×10⁻⁴ kg·m² |
3.2 Robot Selection
The industrial robot must have a payload capacity of at least 150 kg, a working range of at least 2500 mm, and high positioning accuracy. The ABB IRB6700-150 robot satisfies these requirements with a payload of 150 kg, a working range of 3200 mm, and a repeatability of 0.05–0.06 mm. The robot has six degrees of freedom, which provides enough flexibility to simulate human grinding motions. Table 3 lists the joint motion ranges and maximum speeds.
| Axis | Motion range | Maximum speed |
|---|---|---|
| Axis 1 rotation | +170° to -170° | 110°/s |
| Axis 2 arm | +85° to -65° | 110°/s |
| Axis 3 arm | +70° to -180° | 110°/s |
| Axis 4 wrist | +300° to -300° | 190°/s |
| Axis 5 bend | +130° to -130° | 150°/s |
| Axis 6 turn | +360° to -360° | 210°/s |
3.3 Synchronous Belt Drive
The synchronous belt transmits power from the motor to the grinding wheel spindle. A 5M arc-tooth belt was selected. The design power is:
$$P_{ca} = K_A \cdot P = 1.9 \times 3.0 = 5.7\,\text{kW}$$
With a speed ratio of 1.5 and a center distance of 290 mm, the pitch diameters of the small and large pulleys are 57.32 mm and 85.99 mm respectively. The belt pitch length is:
$$L = 2a + \frac{\pi(d_1 + d_2)}{2} + \frac{(d_1 – d_2)^2}{4a}$$
Substituting the values gives \(L \approx 805.7\,\text{mm}\), so I selected a standard 810-5M belt. The required belt width was calculated as:
$$b_s \geq b_{s0} \left( \frac{P_{ca}}{K_z P_0} \right)^{1/1.14}$$
The final width is 30 mm.
3.4 Grinding Wheel Selection
The grinding wheel is the primary tool for material removal. For steel castings, brown corundum (Al₂O₃) abrasive is suitable because of its high toughness and hardness. The grit size was chosen as #30, the hardness grade as L, and the bond type as resin. The wheel dimensions are 300 mm in diameter and 25 mm in thickness. The maximum permissible peripheral speed is 45 m/s, which provides a good balance between grinding efficiency and safety.
3.5 Buffer Structure Design
To protect the robot from impact and vibration, I designed a buffering system using four cylindrical rubber springs in parallel. The design considerations include:
- High static stiffness to minimize deformation under load.
- High damping to absorb shock and reduce vibration transmission.
- Compact dimensions to fit within the robot mounting interface.
Each rubber spring has a height of 40 mm and a diameter of 120 mm. The deformation of a single spring under a force \(F\) is given by:
$$\Delta l = \frac{F l}{E A}$$
For a bending moment, the angular deflection at the free end is:
$$\theta_{BM} = \frac{F L l}{E I}$$
The total displacement at the grinding point is:
$$Z_s = \frac{F l}{E A} + L \sin\left( \frac{F L l}{E I} \right)$$
For the initial design with ordinary rubber (E=6.1 MPa), the calculated displacement was 0.56 mm, which was considered acceptable for static conditions. However, as shown later in the dynamic analysis, ordinary rubber proved too flexible for the actual grinding process.
4. Grinding Efficiency and Grinding Force Experiments
4.1 Experimental Method
For a steel casting, the material removal rate \(V_m\) (mm³/s) is:
$$V_m = v_\omega \cdot a_p \cdot b$$
where \(v_\omega\) is the feed rate (mm/s), \(a_p\) is the grinding depth (mm), and \(b\) is the wheel width (25 mm in this study). The goal was to maximize \(V_m\) under the constraint that the servo motor torque does not exceed 80% of its rated value. I established the following factor ranges based on preliminary tests:
- Grinding depth: \(0.25 \le a_p \le 1.5\) mm
- Wheel speed: \(35.34 \le v_s \le 44.77\) m/s
- Feed rate: determined by the motor torque limit
Single-factor experiments were first conducted to verify that the grinding force increases with grinding depth and feed rate, and decreases with wheel speed. The results confirmed the expected relationships.
4.2 Orthogonal Test for Grinding Efficiency
An \(L_{25}(5^4)\) orthogonal array was used to evaluate four factors at five levels. The factors were grinding depth \(a_p\), wheel speed \(v_s\), feed rate \(v_\omega\), and the response was the material removal rate \(V_m\). During the experiments, I recorded the motor torques and robot joint torques to calculate the grinding forces. Table 4 shows the complete orthogonal test results.
| No. | \(a_p\) (mm) | \(v_s\) (m/s) | \(v_\omega\) (mm/s) | \(V_m\) (mm³/s) | \(T_s\) (N·m) | \(T_2\) (N·m) | \(T_3\) (N·m) |
|---|---|---|---|---|---|---|---|
| 1 | 0.25 | 35.34 | 70 | 437.5 | 15.28 | 9.73 | 11.73 |
| 2 | 0.25 | 37.70 | 73 | 456.25 | 14.32 | 9.59 | 11.52 |
| 3 | 0.25 | 40.05 | 74 | 462.5 | 13.48 | 9.32 | 11.23 |
| 4 | 0.25 | 42.41 | 76 | 475 | 12.72 | 8.80 | 11.09 |
| 5 | 0.25 | 44.77 | 77 | 481.25 | 12.06 | 8.53 | 10.68 |
| 6 | 0.5 | 35.34 | 44 | 550 | 15.28 | 10.42 | 11.69 |
| 7 | 0.5 | 37.70 | 46 | 575 | 14.32 | 9.85 | 11.47 |
| 8 | 0.5 | 40.05 | 48 | 600 | 13.48 | 9.27 | 11.44 |
| 9 | 0.5 | 42.41 | 49 | 612.5 | 12.72 | 9.19 | 11.24 |
| 10 | 0.5 | 44.77 | 51 | 637.5 | 12.06 | 8.84 | 10.90 |
| 11 | 0.8 | 35.34 | 20 | 400 | 15.28 | 10.08 | 11.46 |
| 12 | 0.8 | 37.70 | 22 | 440 | 14.32 | 10.19 | 11.01 |
| 13 | 0.8 | 40.05 | 26 | 520 | 13.48 | 11.06 | 10.36 |
| 14 | 0.8 | 42.41 | 30 | 600 | 12.72 | 11.42 | 10.12 |
| 15 | 0.8 | 44.77 | 32 | 640 | 12.06 | 11.61 | 9.68 |
| 16 | 1.2 | 35.34 | 4 | 120 | 15.28 | 11.59 | 14.02 |
| 17 | 1.2 | 37.70 | 5 | 150 | 14.32 | 11.42 | 13.77 |
| 18 | 1.2 | 40.05 | 6 | 180 | 13.48 | 11.04 | 13.16 |
| 19 | 1.2 | 42.41 | 6 | 180 | 12.72 | 10.72 | 12.29 |
| 20 | 1.2 | 44.77 | 7 | 210 | 12.06 | 10.29 | 12.04 |
| 21 | 1.5 | 35.34 | 2 | 75 | 15.28 | 13.17 | 16.04 |
| 22 | 1.5 | 37.70 | 3 | 112.5 | 14.32 | 12.93 | 15.71 |
| 23 | 1.5 | 40.05 | 3 | 112.5 | 13.48 | 11.72 | 15.29 |
| 24 | 1.5 | 42.41 | 4 | 150 | 12.72 | 11.35 | 14.55 |
| 25 | 1.5 | 44.77 | 5 | 187.5 | 12.06 | 10.04 | 13.97 |
From the orthogonal test, the maximum material removal rate occurred at \(a_p=0.8\) mm, \(v_s=44.77\) m/s, and \(v_\omega=32\) mm/s, giving \(V_m=640\) mm³/s. This condition represents the highest grinding efficiency for the steel casting under the given machine constraints. Compared to manual grinding, which takes 3–5 hours for a typical riser, the robot grinding achieves the same task in about 77 minutes, improving productivity by 2.3 to 3.9 times.
The surface quality was also examined. When \(a_p=0.8\) mm, the ground surface was smooth and bright without burning marks. At \(a_p=1.2\) mm or deeper, the tool vibrated significantly and caused blackening of the steel casting surface. Therefore, \(a_p=0.8\) mm is the recommended grinding depth for optimal both efficiency and surface quality.
4.3 Grinding Force Calculation
The grinding force was decomposed into tangential force \(F_t\), normal force \(F_n\), and axial force \(F_a\). The axial force was negligible. The tangential grinding force was obtained from the servo motor torque \(T_s\):
$$F_t = \frac{T_s \cdot i_{belt}}{r_s}$$
The normal grinding force was calculated from the robot joint torques. The robot was positioned so that only joints 2 and 3 were affected by the grinding force. Using the joint angles and arm lengths, the normal force is:
$$F_n = \sqrt{{F_2′}^2 + {F_3′}^2 + 2F_2′ F_3′ \cos\alpha}$$
where \(F_2′ = T_2 i_2 / l_2\) and \(F_3′ = T_3 i_3 / l_3\). The reducer ratios were measured as \(i_2=50/11\) and \(i_3=25/7\). For the optimal grinding condition, the tangential force was 53.6 N and the normal force was 62.92 N. Table 5 lists the computed grinding forces for all experimental conditions.
| No. | \(a_p\) (mm) | \(v_s\) (m/s) | \(v_\omega\) (mm/s) | \(F_t\) (N) | \(F_n\) (N) |
|---|---|---|---|---|---|
| 1 | 0.25 | 35.34 | 70 | 67.9 | 56.53 |
| 2 | 0.25 | 37.70 | 73 | 63.6 | 59.09 |
| 3 | 0.25 | 40.05 | 74 | 59.9 | 57.50 |
| 4 | 0.25 | 42.41 | 76 | 56.5 | 55.37 |
| 5 | 0.25 | 44.77 | 77 | 53.6 | 53.52 |
| 6 | 0.5 | 35.34 | 44 | 67.9 | 62.45 |
| 7 | 0.5 | 37.70 | 46 | 63.6 | 59.96 |
| 8 | 0.5 | 40.05 | 48 | 59.9 | 57.85 |
| 9 | 0.5 | 42.41 | 49 | 56.5 | 57.13 |
| 10 | 0.5 | 44.77 | 51 | 53.6 | 55.15 |
| 11 | 0.8 | 35.34 | 20 | 67.9 | 61.29 |
| 12 | 0.8 | 37.70 | 22 | 63.6 | 60.35 |
| 13 | 0.8 | 40.05 | 26 | 59.9 | 62.47 |
| 14 | 0.8 | 42.41 | 30 | 56.5 | 63.24 |
| 15 | 0.8 | 44.77 | 32 | 53.6 | 62.92 |
| 16 | 1.2 | 35.34 | 4 | 67.9 | 72.29 |
| 17 | 1.2 | 37.70 | 5 | 63.6 | 71.04 |
| 18 | 1.2 | 40.05 | 6 | 59.9 | 68.41 |
| 19 | 1.2 | 42.41 | 6 | 56.5 | 65.49 |
| 20 | 1.2 | 44.77 | 7 | 53.6 | 63.42 |
| 21 | 1.5 | 35.34 | 2 | 67.9 | 82.33 |
| 22 | 1.5 | 37.70 | 3 | 63.6 | 80.99 |
| 23 | 1.5 | 40.05 | 3 | 59.9 | 75.57 |
| 24 | 1.5 | 42.41 | 4 | 56.5 | 72.77 |
| 25 | 1.5 | 44.77 | 5 | 53.6 | 66.72 |
The range analysis of the orthogonal experiment is summarized in Table 6.
| Indicator | Factor | K1 | K2 | K3 | K4 | K5 | Range |
|---|---|---|---|---|---|---|---|
| \(v_\omega\) (mm/s) | \(a_p\) | 370 | 238 | 130 | 28 | 17 | 353 |
| \(v_\omega\) (mm/s) | \(v_s\) | 140 | 149 | 157 | 165 | 172 | 32 |
| \(V_m\) (mm³/s) | \(a_p\) | 2312.5 | 2975 | 2600 | 840 | 637.5 | 1675 |
| \(V_m\) (mm³/s) | \(v_s\) | 1582.5 | 1733.75 | 1875 | 2017.5 | 2156.25 | 573.75 |
| \(F_n\) (N) | \(a_p\) | 282.01 | 292.54 | 310.27 | 340.65 | 378.38 | 96.37 |
| \(F_n\) (N) | \(v_s\) | 334.89 | 331.43 | 321.80 | 314.00 | 301.73 | 33.16 |
From the range analysis, grinding depth \(a_p\) has a greater influence on both feed rate and material removal rate than wheel speed \(v_s\). This is because at deeper cuts, the feed rate must be reduced to keep the motor torque below the limit, but the product \(a_p \times v_\omega\) is still maximized at an intermediate depth. The results also show that the normal grinding force increases with depth and decreases with wheel speed.
4.4 Empirical Grinding Force Formulas
Based on the grinding force theory and the experimental data, I fitted power-law empirical formulas for the normal and tangential grinding forces. The general forms are:
$$F_n = \lambda_n a_p^{\mu_1} v_s^{\mu_2} v_\omega^{\mu_3}$$
$$F_t = \lambda_t a_p^{\sigma_1} v_s^{\sigma_2} v_\omega^{\sigma_3}$$
Taking logarithms and performing multiple linear regression using MATLAB, the fitted formulas for steel casting ZG15Cr2Mo1 are:
$$F_n = 1.0265 \, a_p^{2.527} \, v_s^{-0.02043} \, v_\omega^{1.5775}$$
$$F_t = 31.1057 \, a_p^{1.28814} \, v_s^{-0.060798} \, v_\omega^{0.53616}$$
These formulas show that the grinding force increases with grinding depth and feed rate, and decreases with wheel speed. The exponent for \(a_p\) in the normal force formula is the largest, confirming that grinding depth dominates the force response. This empirical model provides a useful prediction tool for future process optimization of steel casting grinding.
4.5 Dynamic Impact Load Spectrum
In actual coarse grinding of steel casting risers, the surface is highly irregular, causing dynamic impacts on the grinding wheel. I conducted a rough surface grinding experiment using an actual steel casting riser. The test condition was \(a_p=0.8\) mm, \(v_s=44.77\) m/s, and \(v_\omega=32\) mm/s. The servo motor torque was recorded in real time, and the tangential force was calculated by:
$$F_t = \frac{T_s \cdot i_{belt}}{r_s}$$
Using MATLAB’s Curve Fitting Toolbox, I performed an 8th-order Fourier fit to the force data, yielding the tangential force load spectrum:
$$\begin{aligned}
F_t’ &= 45.97 – 10.68\cos(0.39x) + 10.53\sin(0.39x) \\
&\quad -8.05\cos(0.78x) -0.87\sin(0.78x) \\
&\quad -19.21\cos(1.17x) -8.24\sin(1.17x) \\
&\quad +0.31\cos(1.56x) -7.21\sin(1.56x) \\
&\quad -7.00\cos(1.95x) +1.57\sin(1.95x) \\
&\quad +0.35\cos(2.34x) +5.77\sin(2.34x) \\
&\quad -0.95\cos(2.73x) +0.52\sin(2.73x) \\
&\quad +1.05\cos(3.12x) +2.49\sin(3.12x)
\end{aligned}$$
The Fourier transform revealed that the dominant excitation frequency from the rough steel casting surface is \(f_s = 0.39\) Hz. Since the normal force is typically 1.5–3 times the tangential force, and to ensure a conservative safety factor, I used a ratio of 1.7 to construct the normal force load spectrum:
$$\begin{aligned}
F_n’ &= 78.15 – 18.16\cos(0.39x) + 17.91\sin(0.39x) \\
&\quad -13.69\cos(0.78x) +1.489\sin(0.78x) \\
&\quad -32.66\cos(1.17x) -14.01\sin(1.17x) \\
&\quad +0.5268\cos(1.56x) -12.26\sin(1.56x) \\
&\quad -11.91\cos(1.95x) +2.672\sin(1.95x) \\
&\quad +0.5974\cos(2.34x) +9.81\sin(2.34x) \\
&\quad -1.61\cos(2.73x) +0.8849\sin(2.73x) \\
&\quad +1.782\cos(3.12x) +4.221\sin(3.12x)
\end{aligned}$$
These load spectra were used as input for the finite element transient dynamic analysis of the grinding tool.
5. Finite Element Analysis of the Grinding Tool
5.1 Model Simplification and Meshing
To improve computational efficiency, I simplified the deep groove ball bearings in the grinding tool to equivalent rings. A comparative static analysis showed that the simplified model has negligible differences in the displacement at the shaft end (3.46×10⁻⁷ m vs. 3.11×10⁻⁷ m). The final finite element model of the grinding tool is shown in the analysis software. The model consists of 45 steel components and rubber springs. The material properties are listed in Table 7.
| Material | Density (kg/m³) | Elastic modulus (MPa) | Poisson’s ratio | Yield strength (MPa) |
|---|---|---|---|---|
| Ordinary rubber | 1000 | 6.1 | 0.49 | 9.24 |
| Hard rubber | 1300 | 5.3 | 0.47 | 9.60 |
| 45 steel | 7890 | 2.09×10⁵ | 0.269 | 355 |
5.2 Static Analysis
A static analysis was performed with the tool under gravity and a normal force of 150 N applied at the wheel position. With ordinary rubber springs, the maximum deformation was 3.61×10⁻⁵ m, occurring at the far end of the servo motor. The maximum stress was 95.97 MPa, located at the screws, which is well below the yield strength. With hard rubber springs, the maximum deformation decreased to 3.665×10⁻⁵ m (similar) but the displacement at the wheel shaft was reduced to 4.07×10⁻⁶ m. Both designs satisfy static requirements.
5.3 Modal Analysis
Modal analysis was carried out to determine the natural frequencies of the tool. Table 8 lists the first six natural frequencies for the tool with ordinary rubber springs and with hard rubber springs.
| Mode | Ordinary rubber (Hz) | Hard rubber (Hz) |
|---|---|---|
| 1 | 10.268 | 18.94 |
| 2 | 10.753 | 19.23 |
| 3 | 22.332 | 35.926 |
| 4 | 27.329 | 39.103 |
| 5 | 38.205 | 67.892 |
| 6 | 39.262 | 68.446 |
The dominant excitation frequency from the steel casting surface is only 0.39 Hz, which is far below the lowest natural frequency of the tool (10.268 Hz even with ordinary rubber). Therefore, resonance is unlikely to occur during normal grinding. The hard rubber springs increase the natural frequencies further, improving dynamic stability.
5.4 Transient Dynamic Analysis
The transient response of the tool was evaluated by applying the measured load spectra (both tangential and normal forces) to the grinding wheel shaft. The analysis covered a continuous working period of 350 seconds. With ordinary rubber springs, the maximum deformation reached 0.6 mm, which is 75% of the grinding depth 0.8 mm. This violates the design criterion that the deformation should not exceed one-third of the grinding depth. Thus, ordinary rubber was deemed too soft for the coarse grinding of steel castings.
I then replaced the rubber spring material with a harder rubber compound (E=5.3 MPa but with higher stiffness due to its structural behavior). The transient analysis showed a maximum deformation of 0.229 mm, which is less than 0.27 mm (one-third of 0.8 mm). The maximum dynamic stress was 2.61 MPa, far below the yield strength. The optimization successfully balanced stiffness and damping.
5.5 Experimental Verification of Buffer Materials
To verify the simulation results, I performed actual grinding experiments with three configurations: ordinary rubber springs, hard rubber springs, and no buffer springs. The grinding depth was set to 1.2 mm and the wheel speed to 37.68 m/s to amplify the effects. The feed rate was gradually increased while monitoring the motor torque fluctuations.
| Configuration | Torque fluctuation | Surface quality | Stability |
|---|---|---|---|
| Ordinary rubber | Significant after 17 mm/s | Blackening at end | Unstable at higher loads |
| Hard rubber | Smooth throughout | Excellent, no darkening | Stable |
| No buffer | Large fluctuations | Poor, visible vibration marks | Unstable |
The experiments confirmed that hard rubber springs provide the optimal balance between “soft” vibration absorption and “stiff” structural support. The torque fluctuation curve for the hard rubber configuration remained nearly constant, demonstrating reliable performance during continuous grinding of steel casting risers.
6. Conclusion and Future Work
In this research, I successfully designed and validated a robot-mounted coarse grinding tool specifically for steel castings. The main conclusions are as follows:
- The proposed grinding tool uses a servo motor as the direct driving source and a cylindrical grinding wheel instead of a thin disc wheel. This design significantly improves the material removal capability and enables real-time grinding force monitoring without a costly force sensor.
- By using an orthogonal experiment, I found that the optimal grinding conditions for steel casting ZG15Cr2Mo1 are a grinding depth of 0.8 mm, a wheel speed of 44.77 m/s, and a feed rate of 32 mm/s. This yields the maximum material removal rate of 640 mm³/s, which is 2.3–3.9 times faster than manual grinding.
- I derived empirical grinding force formulas for both tangential and normal forces. These formulas show that grinding depth has the strongest influence on grinding force.
- The rough surface of steel casting risers produces a dynamic excitation frequency of 0.39 Hz, which is far below the natural frequency of the grinding tool, thereby avoiding resonance.
- Finite element transient analysis revealed that ordinary rubber is too flexible for the coarse grinding process. Replacing it with a harder rubber compound reduced the maximum deformation from 0.6 mm to 0.229 mm, meeting the design criterion of one-third of the grinding depth.
- Actual grinding experiments with three different buffer configurations confirmed that hard rubber springs provide the best combination of rigidity and shock absorption, ensuring stable and reliable operation for steel casting grinding.
Future work will focus on reducing the weight and size of the grinding tool, integrating machine vision for automatic path planning, and adding a rotary table to create a fully automated grinding cell. These improvements will further enhance the efficiency and competitiveness of robotic steel casting grinding in modern foundries.