
In my research on improving the quality of sand castings, particularly for large components like machine tool beds, I have focused on the critical role of filling speed control during the casting process. Sand castings are a fundamental method in metalworking, where molten metal fills a mold cavity under gravity. This technique is widely used due to its versatility—it can produce complex parts ranging from small items to massive structures like bed frames and housings. The advantages of sand castings include the ability to create intricate geometries, cost-effectiveness from readily available materials, and high precision that minimizes post-processing. However, controlling the filling speed is paramount; improper management can lead to defects such as deformation and cracks on the casting surface, ultimately compromising the mechanical properties of the final product. In this article, I delve into the entire process of sand castings for machine tool beds, develop mathematical models for filling dynamics, implement PLC-based control systems, and conduct error simulations to optimize performance. Through this exploration, I aim to demonstrate how advanced control strategies can enhance the reliability of sand castings in industrial applications.
The process of creating machine tool beds via sand castings involves a series of meticulously coordinated steps. Based on my experience, I outline the workflow as follows. It begins with designing the part using computer-aided tools to generate precise drawings. Next, cores are made by packing resin-bonded sand into molds to form internal cavities of the casting. The molding phase involves preparing the sand mold and pouring molten metal into it. After solidification, the mold is broken to remove the sand, and the casting is cleaned and inspected for quality. To summarize these stages, I present a table that encapsulates the key activities and their purposes in sand castings for machine tool beds.
| Step | Description | Purpose in Sand Castings |
|---|---|---|
| 1. Design and Drafting | Creating detailed CAD models of the machine tool bed. | To define geometry and ensure accuracy in sand castings. |
| 2. Core Making | Forming internal cavities using resin sand in molds. | To shape complex internal features in sand castings. |
| 3. Molding and Pouring | Preparing the sand mold and filling it with molten metal. | To transfer the liquid metal into the mold cavity in sand castings. |
| 4. Shakeout and Cleaning | Breaking the mold to extract the casting and removing residual sand. | To retrieve the final part from sand castings. |
| 5. Inspection and Testing | Checking for defects like cracks or porosity. | To ensure quality standards in sand castings are met. |
This streamlined approach is essential for producing high-quality sand castings, but it hinges on precise control during the pouring phase. In my work, I have observed that the filling speed directly influences thermal stress distribution, which can cause surface imperfections if not managed properly. Therefore, understanding the fluid dynamics involved is crucial. The filling process in sand castings is governed by hydrodynamic principles, where the metal flow depends on the pressure head and system resistance. When molten metal fills the mold cavity below the ingate, the pressure head remains constant, but for sections above the ingate, it varies dynamically. To model this, I derive equations based on Bernoulli’s principle. For a typical sand castings setup, the total head \( H \) is related to the outflow velocity \( \nu \) from the ingate as follows:
$$ H = \frac{\nu^2}{2g} + \Delta h $$
Here, \( g \) represents the gravitational acceleration, and \( \Delta h \) denotes the head loss due to friction and other resistances in the sand castings system. The head loss can be expressed in terms of a local damping coefficient \( \lambda \):
$$ \Delta h = \lambda \frac{\nu^2}{2g} $$
Substituting this into the first equation, I obtain:
$$ H = \frac{\nu^2}{2g} (1 + \lambda) $$
Solving for the ingate exit velocity, which is critical for controlling filling speed in sand castings, yields:
$$ \nu = \sqrt{\frac{2gH}{1+\lambda}} $$
Furthermore, the weight of metal flowing through the ingate to fill the cavity below can be calculated to assess the filling rate. For sand castings, this is given by:
$$ G = \rho A t \sqrt{\frac{2gH}{1+\lambda}} $$
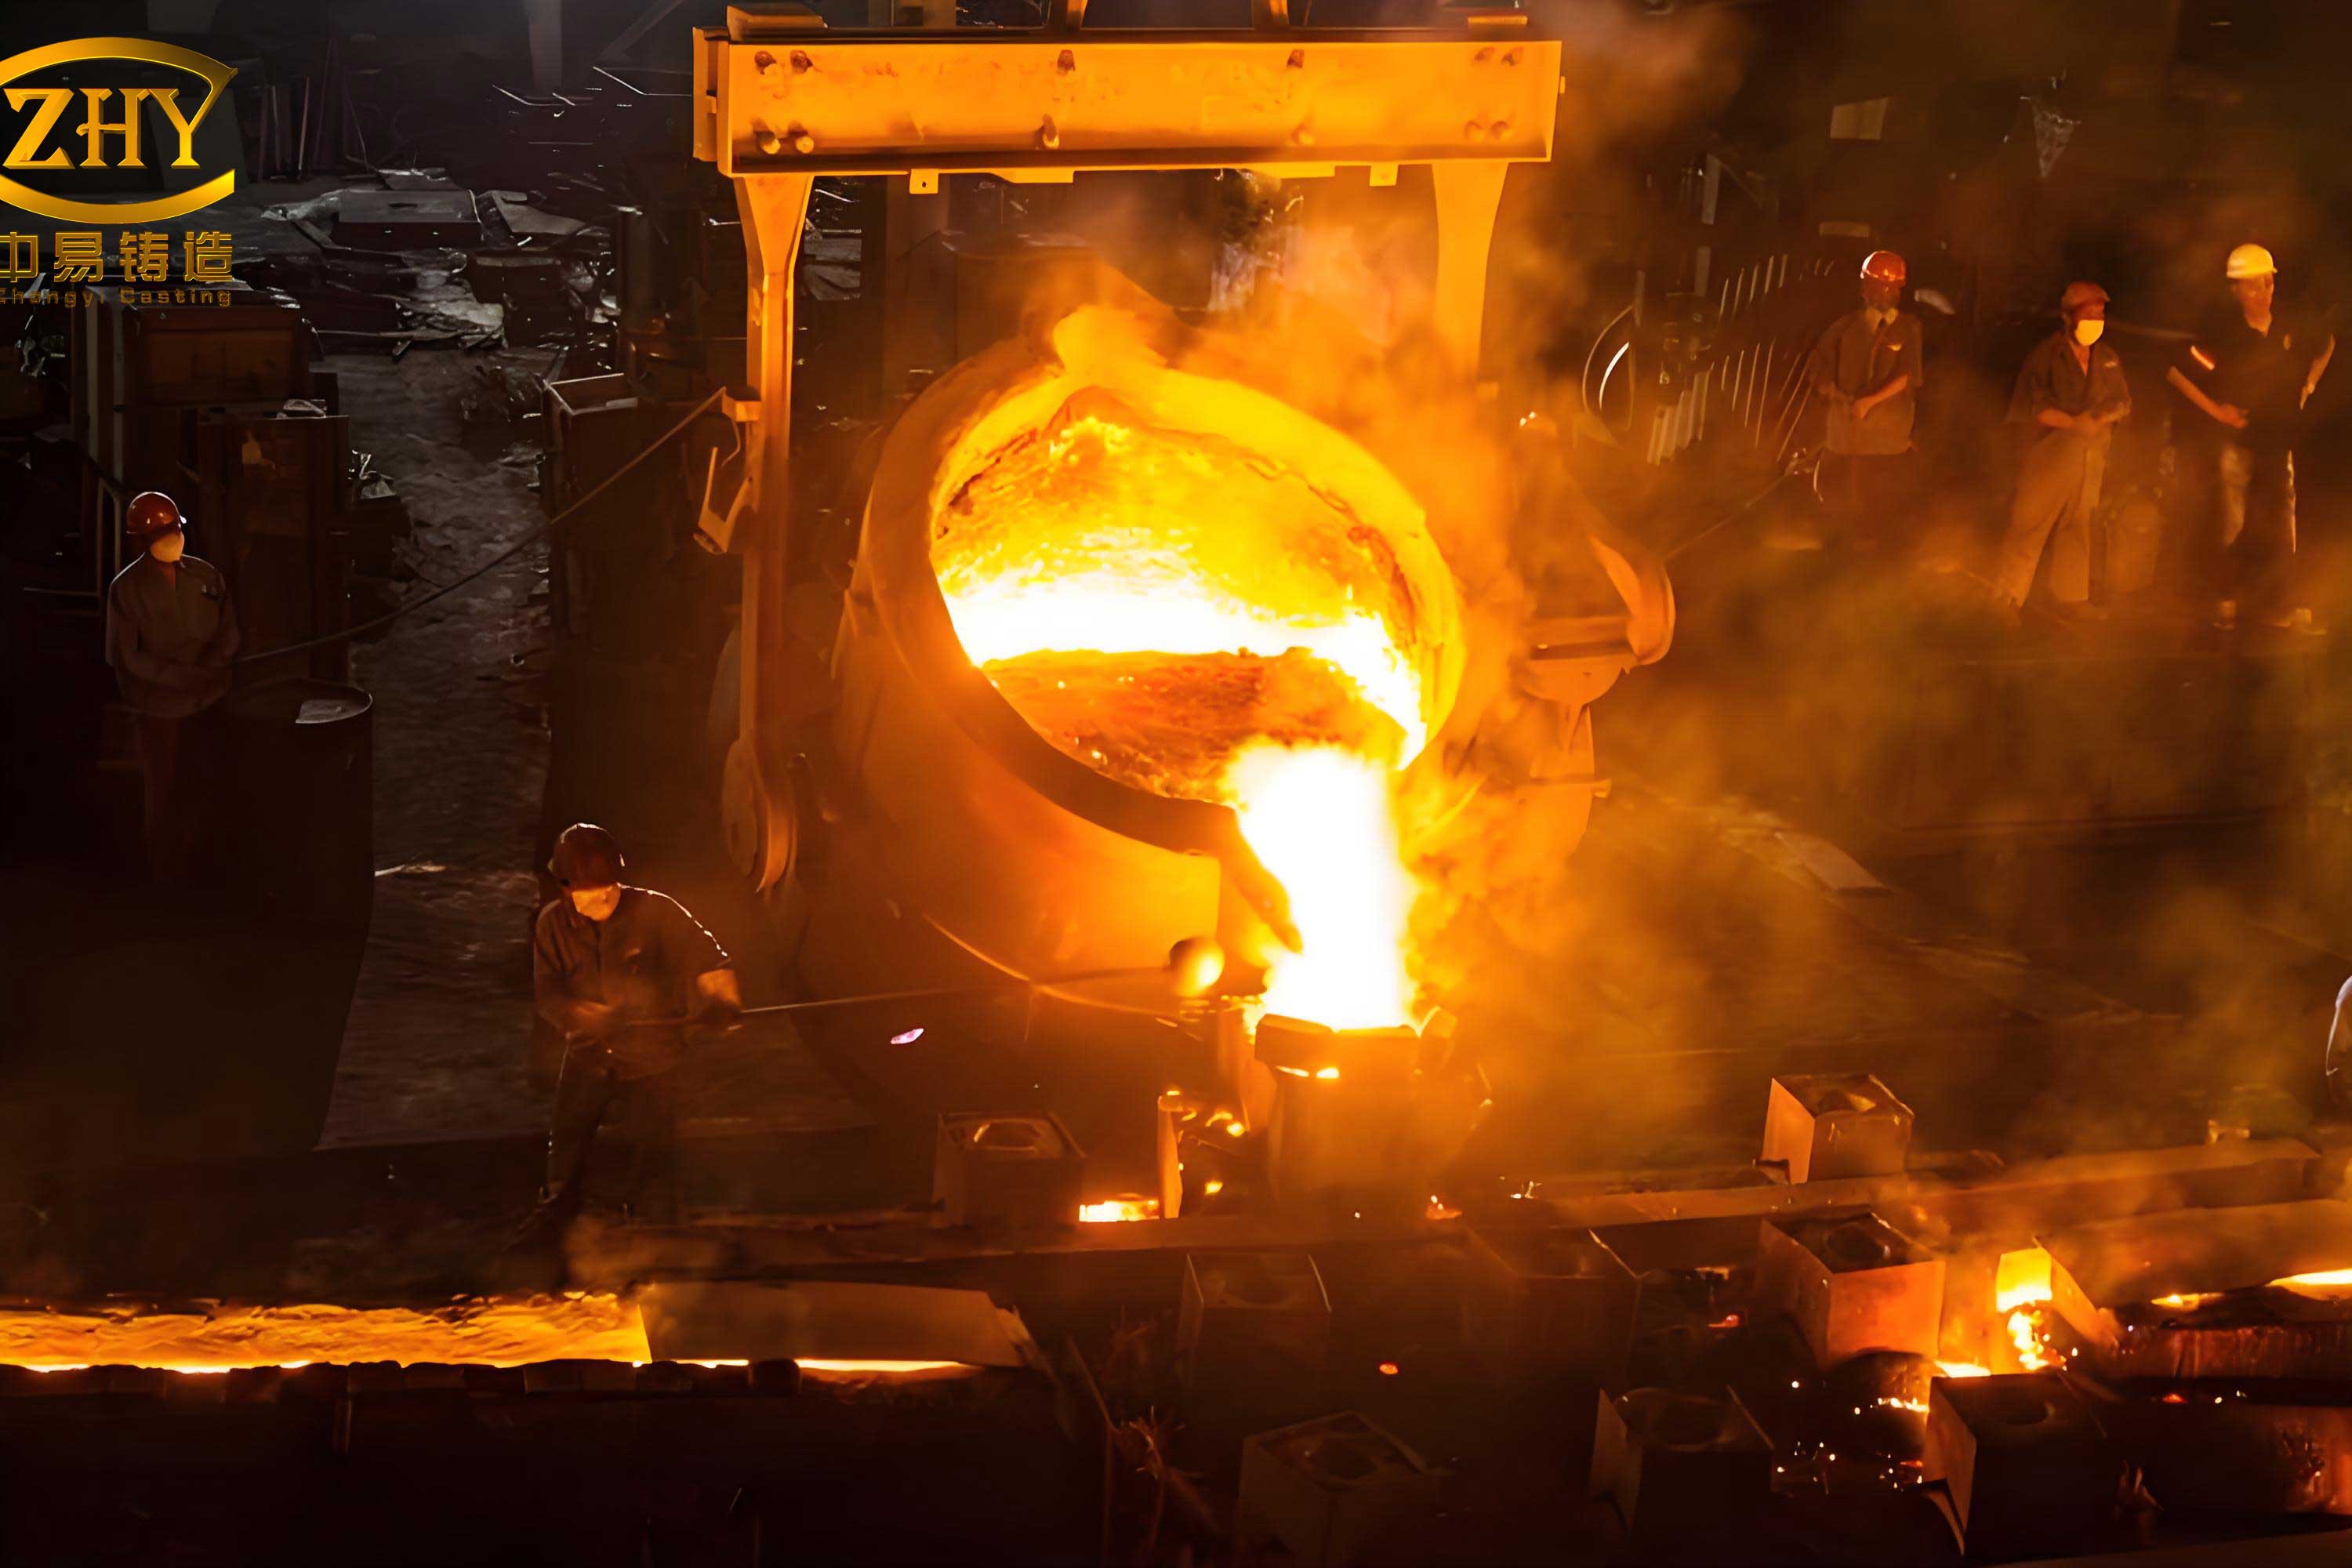
In this equation, \( G \) is the weight of metal, \( \rho \) is the density of the molten metal, \( A \) is the cross-sectional area of the ingate, and \( t \) is the time required to fill the lower cavity. These formulas provide a foundation for simulating and controlling the filling speed in sand castings, allowing me to predict and minimize errors. To illustrate the application of sand castings in industry, consider the following image showcasing various sand casting parts, which highlights the diversity and complexity achievable with this method.
Building on these equations, I have implemented a Programmable Logic Controller (PLC) system to regulate the filling speed in sand castings for machine tool beds. Traditional methods like PI control often lead to instability and larger errors, prompting me to explore PLC-based solutions for better precision. The PLC software I designed consists of two main components: an interface management program and a monitoring program. The interface program handles communication with external devices, receiving remote commands for scanning, operations, and mode settings. It processes these inputs, collects data from sensors, and transmits results such as instrument status and processed measurements. For sand castings, the programming considers specific control objectives, including filling speed and casting length. I start by drafting electrical control schematics, assigning tasks to internal components, and then coding in PLC languages like ladder logic or function block diagrams. After simulation and debugging, the program is downloaded to memory modules for real-time execution. This approach ensures robust control in sand castings applications.
The configuration of the measurement and control system for sand castings involves several PLC modules tailored to the process. In my setup, I use a CPU module (e.g., CQM1-CPU41) for central processing, along with input modules like D212 for switch signals, output modules such as OC22 for relays and OD212 for transistors, and D/A converters like DA021 for analog outputs. A power module PS02 supplies energy, and an LED display panel shows real-time parameters. For monitoring filling speed in sand castings, a turbine flow meter coupled with an encoder detects the return flow rate; as flow increases, the encoder outputs more pulses to a PLC counter. The display is segmented to show both set and actual filling speeds, enabling operators to adjust parameters dynamically. This system enhances the accuracy of sand castings by minimizing deviations during metal pouring. To quantify the performance, I define key parameters for simulation in sand castings, as summarized in the table below.
| Parameter | Symbol | Value | Role in Sand Castings |
|---|---|---|---|
| Pouring Temperature | \( T \) | 1400 °C | Affects fluidity and solidification in sand castings. |
| Specific Heat Capacity | \( C \) | 850 J·kg⁻¹·K⁻¹ | Influences thermal dynamics during sand castings. |
| Metal Density | \( \rho \) | 7.0 × 10³ kg·m⁻³ | Determines mass flow in sand castings. |
| Thermal Conductivity | \( \lambda \) | 47.2 W·m⁻¹·K⁻¹ | Governs heat transfer in sand castings molds. |
| Solidification Shrinkage | \( \delta \) | 1.5 % | Impacts dimensional accuracy of sand castings. |
| Heat Transfer Coefficient | \( k \) | 155 W·m⁻¹·K⁻¹ | Affects cooling rates in sand castings. |
| Filling Time | \( \Delta t \) | 10 s | Critical for speed control in sand castings. |
With these parameters, I conducted error simulations using MATLAB software to compare PLC and PI control strategies for sand castings. The filling speed error is defined as the deviation between the setpoint and actual velocity during pouring. For PLC-controlled sand castings, I modeled the system with feedback loops that adjust the flow based on real-time sensor data. The error dynamics can be described by a differential equation that incorporates the damping from the sand castings environment. Assuming a first-order system for simplicity, the error \( e(t) \) over time \( t \) is given by:
$$ e(t) = \nu_{\text{set}} – \nu_{\text{actual}}(t) $$
where \( \nu_{\text{set}} \) is the desired filling speed, and \( \nu_{\text{actual}}(t) \) is derived from the PLC output. Using the parameters from the table, I simulated the response over a 10-second filling period. For PLC control in sand castings, the error remained minimal, with a maximum value of approximately \( 1.8 \times 10^{-4} \, \text{m/s} \), indicating stable operation. In contrast, for PI-controlled sand castings, the error peaked at around \( 3.6 \times 10^{-2} \, \text{m/s} \), showing significant fluctuations. This contrast underscores the superiority of PLC for precision in sand castings. To further analyze, I formulated the error reduction ratio \( R \) as:
$$ R = \frac{e_{\text{PI}} – e_{\text{PLC}}}{e_{\text{PI}}} \times 100\% $$
where \( e_{\text{PI}} \) and \( e_{\text{PLC}} \) are the maximum errors for PI and PLC control, respectively. Plugging in the values from my simulation for sand castings:
$$ R = \frac{3.6 \times 10^{-2} – 1.8 \times 10^{-4}}{3.6 \times 10^{-2}} \times 100\% \approx 99.5\% $$
This remarkable reduction highlights how PLC systems can nearly eliminate filling speed errors in sand castings. Additionally, I examined the stress distribution within the casting using thermal-stress coupling models. The von Mises stress \( \sigma \) during solidification in sand castings can be approximated by:
$$ \sigma = \sqrt{\frac{(\sigma_x – \sigma_y)^2 + (\sigma_y – \sigma_z)^2 + (\sigma_z – \sigma_x)^2 + 6(\tau_{xy}^2 + \tau_{yz}^2 + \tau_{zx}^2)}{2}} $$
where \( \sigma_x, \sigma_y, \sigma_z \) are normal stresses and \( \tau_{xy}, \tau_{yz}, \tau_{zx} \) are shear stresses, all influenced by the filling speed. With PLC control in sand castings, the stress concentrations were lower, reducing the risk of cracks. I compiled the simulation outcomes in the following table to provide a clear comparison for sand castings applications.
| Aspect | PLC Control in Sand Castings | PI Control in Sand Castings |
|---|---|---|
| Maximum Filling Speed Error | \( 1.8 \times 10^{-4} \, \text{m/s} \) | \( 3.6 \times 10^{-2} \, \text{m/s} \) |
| Error Stability | High (steady over time) | Low (fluctuating) |
| Stress Concentration | Minimized, uniform distribution | Pronounced, leading to hot spots |
| Surface Quality | Improved, fewer defects | Reduced, prone to cracks |
| Control Response Time | Fast, adaptive to changes | Slower, with overshoot |
The results clearly demonstrate that PLC control significantly enhances the quality of sand castings by ensuring a stable filling speed. This stability prevents uneven thermal stresses, which are a common cause of surface defects in sand castings. In practice, for machine tool beds produced via sand castings, this translates to better mechanical performance and longer service life. My simulations also considered variations in mold geometry and metal properties, reinforcing the robustness of PLC across different sand castings scenarios. For instance, when the ingate area \( A \) changes due to wear in sand castings molds, the PLC system can compensate by adjusting the flow rate, whereas PI control might struggle with such disturbances. This adaptability is crucial for industrial sand castings where conditions are rarely ideal.
Beyond simulation, I have explored practical implementations of PLC in sand castings foundries. The integration of sensors for real-time monitoring allows for closed-loop control that continuously optimizes the filling process. In sand castings, factors like metal temperature and viscosity can vary, but a well-tuned PLC can account for these by modifying the output signals to actuators such as valves or pumps. The mathematical basis for this adaptive control involves a transfer function \( G(s) \) that relates the input command to the filling speed output. For sand castings, I approximate \( G(s) \) as:
$$ G(s) = \frac{K e^{-Ls}}{\tau s + 1} $$
where \( K \) is the gain, \( \tau \) is the time constant, and \( L \) is the dead time inherent in sand castings systems due to fluid inertia. The PLC uses this model to predict and correct errors, ensuring smoother pours in sand castings. Additionally, I have developed algorithms to log data from multiple sand castings runs, enabling statistical analysis for further refinement. For example, by analyzing the error distribution over hundreds of sand castings cycles, I can identify trends and preemptively adjust control parameters. This data-driven approach is revolutionizing how sand castings are managed, moving from trial-and-error to predictive precision.
In conclusion, my research underscores the importance of advanced control systems in sand castings, especially for critical components like machine tool beds. By employing PLC technology, I have shown that filling speed errors can be drastically reduced, leading to more stable processes and higher-quality sand castings. The equations and simulations presented here provide a framework for optimizing sand castings operations, while the comparison with PI control highlights the tangible benefits of modernization. As sand castings continue to evolve with digital tools, integrating PLCs with real-time monitoring will become standard practice, enhancing efficiency and reliability across the industry. Ultimately, this work contributes to the broader goal of perfecting sand castings techniques, ensuring they meet the stringent demands of modern manufacturing.