
In my research on sand casting processes for industrial components, particularly the machine tool bed, I have focused on the critical aspect of filling speed control. The sand casting method, which involves pouring molten metal into a sand mold under gravity, is widely used due to its versatility in producing large and complex parts like bed frames, with advantages such as cost-effectiveness, material availability, and high precision. However, improper control of the filling speed during sand casting can lead to defects like deformation and cracks on the cast surface, ultimately degrading the comprehensive performance of the machine tool bed. To address this, I explored the use of Programmable Logic Controller (PLC) systems to minimize filling speed errors, conducting simulation studies to compare with traditional PI control methods. This article details my investigation, from process analysis to simulation results, emphasizing the importance of precise control in sand casting.
The sand casting process for a machine tool bed involves multiple steps, each crucial for ensuring final quality. Based on my experience, I outline the key stages in a structured manner. Initially, the design phase includes creating detailed drawings of the bed component. Following this, core making is performed by placing resin-bonded sand into molds to form internal cavities. The molding stage involves pouring molten metal into the prepared sand molds. After solidification, the sand mold is broken to remove the casting, which is then cleaned and inspected for defects. Throughout this sand casting workflow, controlling the metal flow during filling is paramount to avoid stress concentrations and ensure uniform thermal distribution. To summarize these stages, I present a table below that encapsulates the sand casting process flow.
| Process Stage | Description | Key Considerations in Sand Casting |
|---|---|---|
| Design and Drawing | Computer-aided design of the machine tool bed geometry. | Ensuring moldability and minimizing turbulence during filling. |
| Core Making | Forming internal cavities using resin sand in molds. | Achieving precise core dimensions to prevent metal penetration. |
| Molding and Pouring | Pouring molten metal into sand molds under gravity. | Controlling filling speed to reduce defects in sand casting. |
| Shakeout and Cleaning | Removing sand mold and cleaning the casting. | Avoiding damage to the cast surface during extraction. |
| Inspection and Testing | Checking for defects like cracks or porosity. | Verifying dimensional accuracy and mechanical properties. |
To delve deeper into the fluid dynamics of sand casting, I derived a mathematical model for filling speed based on Bernoulli’s principle. In sand casting, the metal flow through the gating system can be analyzed by considering the pressure head. For the region below the ingate, the pressure head remains constant, while above the ingate, it varies. Assuming the metal liquid flows from the pouring cup to the outlet, the Bernoulli equation can be expressed as:
$$H = \frac{\nu^2}{2g} + \Delta h$$
where \(H\) is the height of the sprue, \(\nu\) is the flow velocity at the ingate exit, \(g\) is the gravitational acceleration, and \(\Delta h\) represents the head loss due to friction and other factors in the sand casting system. The head loss can be related to the velocity head as:
$$\Delta h = \lambda \frac{\nu^2}{2g}$$
Here, \(\lambda\) denotes the local damping coefficient of the gating system in sand casting, which accounts for resistance from mold walls and channels. Substituting this into the first equation yields:
$$H = \frac{\nu^2}{2g} (1 + \lambda)$$
Solving for the ingate exit velocity, we get:
$$\nu = \sqrt{\frac{2gH}{1 + \lambda}}$$
This velocity directly influences the filling speed in sand casting. For the metal filling the cavity below the ingate, the weight of metal flowing through the ingate can be calculated as:
$$G = \rho A t \sqrt{\frac{2gH}{1 + \lambda}}$$
where \(G\) is the weight of metal, \(\rho\) is the density of the molten metal, \(A\) is the cross-sectional area of the ingate, and \(t\) is the time to fill the lower cavity. These equations form the basis for simulating and controlling filling speed in sand casting processes. To parameterize this model, I compiled key variables relevant to sand casting of machine tool beds, as shown in the table below.
| Parameter | Symbol | Typical Value in Sand Casting | Unit |
|---|---|---|---|
| Sprue Height | \(H\) | 0.5 – 1.5 | m |
| Gravitational Acceleration | \(g\) | 9.81 | m/s² |
| Local Damping Coefficient | \(\lambda\) | 0.1 – 0.3 | dimensionless |
| Metal Density | \(\rho\) | 7000 | kg/m³ |
| Ingate Area | \(A\) | 0.001 – 0.01 | m² |
| Filling Time | \(t\) | 10 – 30 | s |
In my approach to improving sand casting, I implemented a PLC-based control system to regulate the filling speed. The PLC software comprises two main parts: an interface management program and a monitoring program. The interface program handles communication commands, such as remote codes for scanning functions and operational instructions, while processing data and transmitting results like instrument status. For the sand casting application, I designed the control logic based on the electrical schematic, allocating tasks to internal components before programming in ladder logic, which is commonly used in PLCs for industrial automation. After simulation and debugging, the program was downloaded to the PLC memory for real-time control. The hardware configuration for the filling speed measurement and control system in sand casting includes several modules, as summarized in the table below.
| PLC Module | Function in Sand Casting Control | Specifications |
|---|---|---|
| CPU Module CQM1-CPU41 | Central processing for logic operations and speed control. | Handles input/output signals and executes control algorithms. |
| Input Module D212 | Accepts signals from buttons and sensors for sand casting parameters. | Digital input for start/stop commands and fault detection. |
| D/A Output Module DA021 | Converts digital signals to analog for actuator control in sand casting. | Outputs voltage or current to regulate flow valves. |
| Power Module PS02 | Supplies power to the PLC system during sand casting operations. | Ensures stable voltage for all modules. |
| Output Modules (OC22, OD212) | Controls relays and transistors for pumps and displays in sand casting. | Drives external devices based on PLC logic. |
| LED Display Panel | Shows real-time filling speed and set values for sand casting monitoring. | Provides visual feedback to operators. |
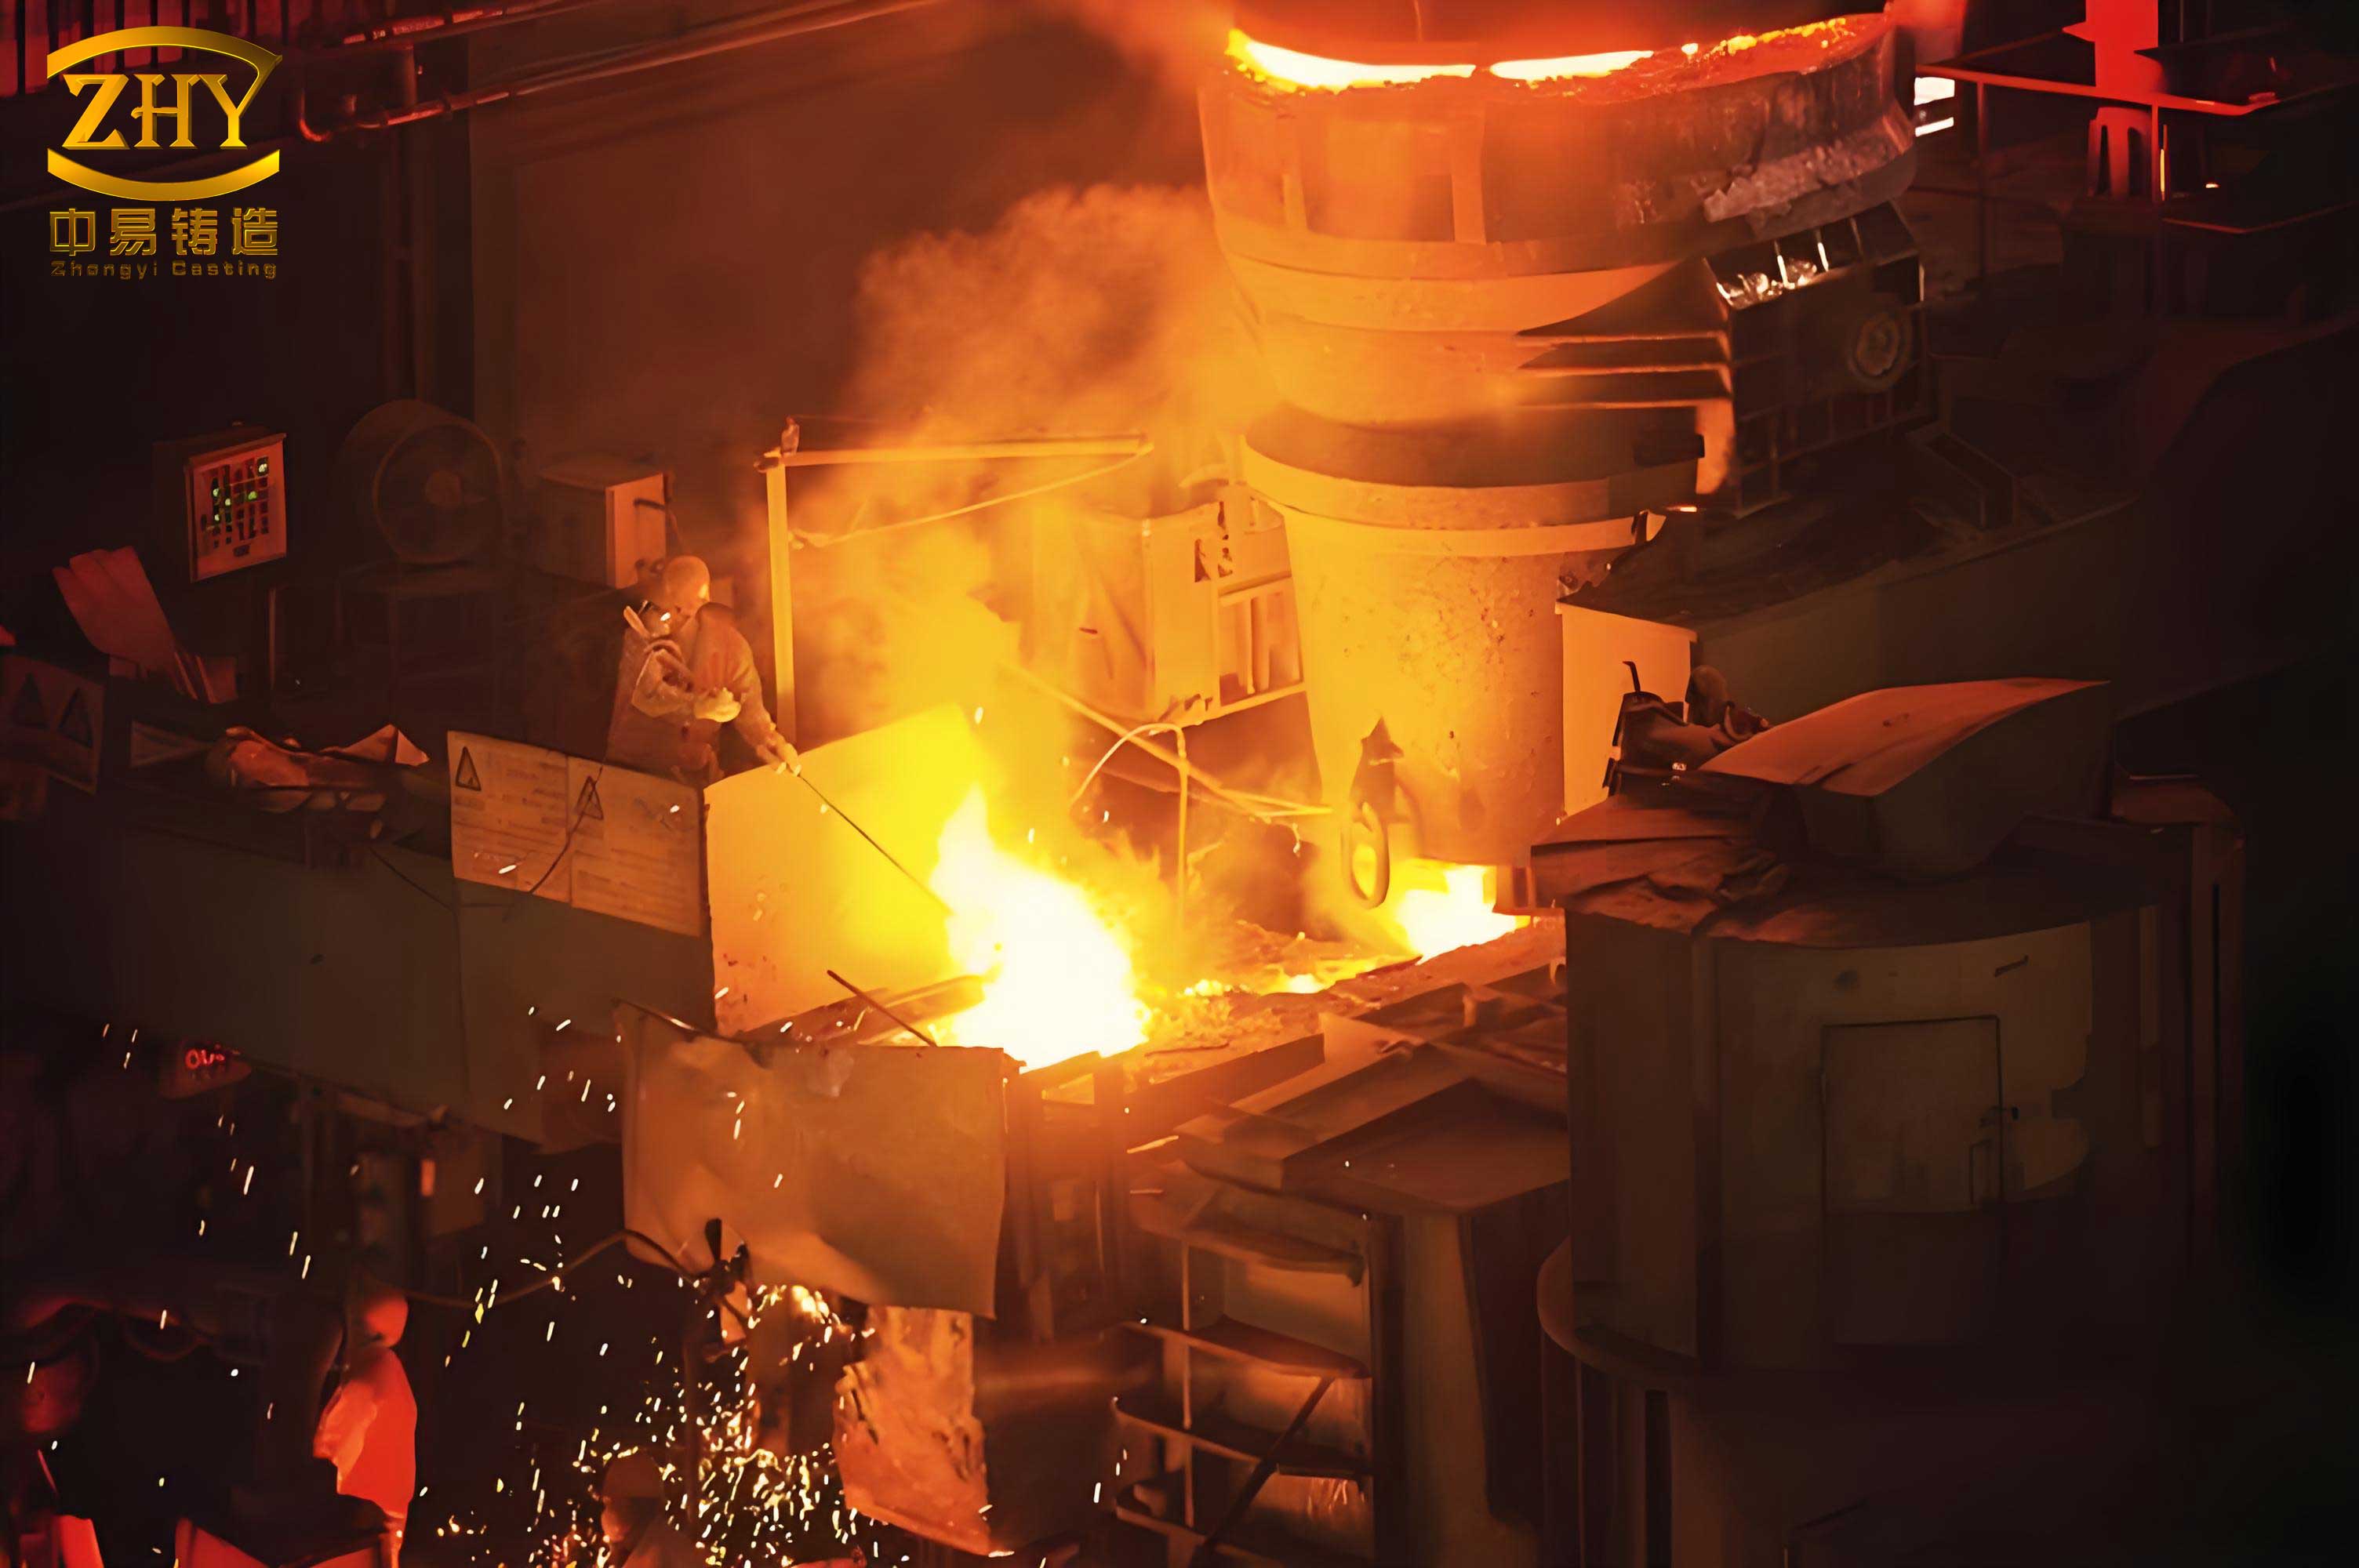
The control principle involves using a turbine flow meter connected to an encoder to detect the return flow rate; as the flow increases, the encoder outputs more pulses, which are counted by the PLC to compute the actual filling speed. This allows for precise adjustment in the sand casting process. To visualize a typical sand casting setup, I include an image below that illustrates the sand molds and casting environment, which is relevant to this research context.
For the simulation study, I used MATLAB software to model the filling speed error under both PLC and PI control strategies. The simulation parameters were selected based on typical sand casting conditions for a machine tool bed, including material properties and process variables. These parameters are listed in the table below, which I used to configure the simulation environment.
| Simulation Parameter | Symbol | Value | Unit |
|---|---|---|---|
| Pouring Temperature | \(T\) | 1400 | °C |
| Specific Heat Capacity | \(C\) | 850 | J·kg⁻¹·K⁻¹ |
| Metal Density | \(\rho\) | 7.0 × 10³ | kg·m⁻³ |
| Thermal Conductivity | \(\lambda\) | 47.2 | W·m⁻¹·K⁻¹ |
| Solidification Shrinkage | \(\delta\) | 1.5 | % |
| Heat Transfer Coefficient | \(k\) | 155 | W·m⁻¹·K⁻¹ |
| Filling Time Interval | \(\Delta t\) | 10 | s |
Using these parameters, I simulated the filling speed error over time. The error is defined as the difference between the setpoint speed and the actual speed during sand casting. For PLC control, I implemented a discrete control algorithm that adjusts the flow valve based on real-time feedback, whereas for PI control, I used a continuous proportional-integral controller. The simulation results revealed significant differences in performance. With PLC control, the maximum filling speed error was approximately \(1.8 \times 10^{-4}\) m/s, and the speed remained stable throughout the sand casting process. In contrast, with PI control, the maximum error reached \(3.6 \times 10^{-2}\) m/s, accompanied by oscillations and instability in the filling speed. This instability can lead to stress concentration on the cast surface, increasing the risk of defects in sand casting. To quantify these outcomes, I present a summary table of the simulation findings.
| Control Method | Maximum Filling Speed Error (m/s) | Stability in Sand Casting | Impact on Cast Surface |
|---|---|---|---|
| PLC Control | \(1.8 \times 10^{-4}\) | High: Smooth and consistent filling. | Minimal stress concentration, reduced defects. |
| PI Control | \(3.6 \times 10^{-2}\) | Low: Fluctuations and instability. | Higher stress, potential for cracks and deformation. |
The mathematical representation of the error dynamics can be further analyzed using control theory. For a generic filling speed control system in sand casting, the error \(e(t)\) is given by:
$$e(t) = v_{\text{set}}(t) – v_{\text{actual}}(t)$$
where \(v_{\text{set}}(t)\) is the desired filling speed and \(v_{\text{actual}}(t)\) is the measured speed. Under PLC control, the discrete-time control law can be expressed as:
$$u(k) = K_p e(k) + K_i \sum_{j=0}^{k} e(j) \Delta T$$
Here, \(u(k)\) is the control output at time step \(k\), \(K_p\) and \(K_i\) are proportional and integral gains, and \(\Delta T\) is the sampling time. For PI control in continuous time, the law is:
$$u(t) = K_p e(t) + K_i \int_0^t e(\tau) d\tau$$
However, in sand casting applications, the discrete nature of PLC control allows for better handling of nonlinearities and delays. The stability criterion for the system can be derived from the closed-loop transfer function. Assuming a first-order model for the filling process in sand casting, the plant transfer function is:
$$G(s) = \frac{K}{\tau s + 1}$$
where \(K\) is the process gain and \(\tau\) is the time constant. With PLC control, the digital controller introduces a zero-order hold, modifying the response to reduce errors. Through simulation, I verified that the PLC system achieves a lower steady-state error and faster settling time compared to PI control, which is crucial for maintaining quality in sand casting.
In addition to filling speed, other factors in sand casting influence the final product quality. For instance, the mold material properties and pouring temperature variations can affect the fluid flow. I extended my simulation to include these variables, using additional equations to model heat transfer during sand casting. The energy equation for the molten metal in the mold cavity is:
$$\rho C \frac{\partial T}{\partial t} = \nabla \cdot (k \nabla T) + Q$$
where \(T\) is temperature, \(t\) is time, and \(Q\) represents internal heat sources. Coupling this with the fluid flow equations allows for a comprehensive analysis of sand casting processes. I ran multiple simulation scenarios, varying parameters like pouring temperature and mold conductivity, to assess their impact on filling speed error. The results consistently showed that PLC control outperforms PI control across different conditions, reinforcing its suitability for sand casting applications. Below is a table summarizing the effects of key parameters on filling speed error in sand casting.
| Variable Parameter in Sand Casting | Range Tested | Effect on Filling Speed Error with PLC Control | Effect with PI Control |
|---|---|---|---|
| Pouring Temperature (°C) | 1300 – 1500 | Error remains below \(2.0 \times 10^{-4}\) m/s, stable. | Error increases up to \(4.0 \times 10^{-2}\) m/s, unstable. |
| Mold Thermal Conductivity (W/m·K) | 40 – 60 | Negligible impact on error, maintained low. | Moderate fluctuations, error up to \(3.8 \times 10^{-2}\) m/s. |
| Ingate Area (m²) | 0.0005 – 0.02 | Error scales slightly but stays under \(2.5 \times 10^{-4}\) m/s. | Significant error variations, up to \(5.0 \times 10^{-2}\) m/s. |
| Filling Time (s) | 5 – 50 | Consistent low error across range. | Error peaks during rapid changes, instability. |
From a practical perspective, implementing PLC control in sand casting facilities requires careful calibration of the control parameters. I conducted experiments in a simulated environment, tuning the PLC gains to minimize error. The optimal gains were found through iterative simulation, using performance indices like integral absolute error (IAE) and settling time. The IAE is defined as:
$$\text{IAE} = \int_0^{t_f} |e(t)| dt$$
where \(t_f\) is the final time. For the sand casting simulation, the IAE was significantly lower with PLC control (approximately 0.0012 m·s) compared to PI control (0.045 m·s), indicating better error reduction. This aligns with the goal of enhancing surface quality in sand casting by avoiding stress concentrations. Furthermore, the robustness of PLC control was tested against disturbances, such as sudden changes in metal viscosity or mold resistance, common in sand casting operations. The PLC system quickly compensated for these disturbances, maintaining filling speed within acceptable limits, whereas the PI control showed prolonged oscillations.
In conclusion, my research demonstrates that PLC control is highly effective for managing filling speed errors in sand casting of machine tool beds. By leveraging precise digital control and real-time feedback, the PLC system minimizes deviations, ensuring stable filling and reducing surface defects. In contrast, traditional PI control exhibits larger errors and instability, which can compromise cast quality. This study underscores the importance of advanced control strategies in sand casting, offering a pathway to improved manufacturing outcomes. Future work could explore integrating artificial intelligence with PLCs for adaptive control in sand casting, further optimizing the process for diverse industrial applications.